Hello! 👋
I'm Joshua McConkie
Robotics & Autonomy | Applied Mathematics Student
Brigham Young University · Expected graduation: April 2028
Robotics Research Assistant at FRoST · Incoming Engineering Intern, State Estimation at Shield AI (Summer 2027)
About Me

I study applied and computational mathematics at BYU (ACME), with interests in robotics and autonomy. I’m the Perception Lead for BYU’s RoboBoat Team, and my projects range from a camera-guided balancing system to a multi-agent coverage simulator.
Projects


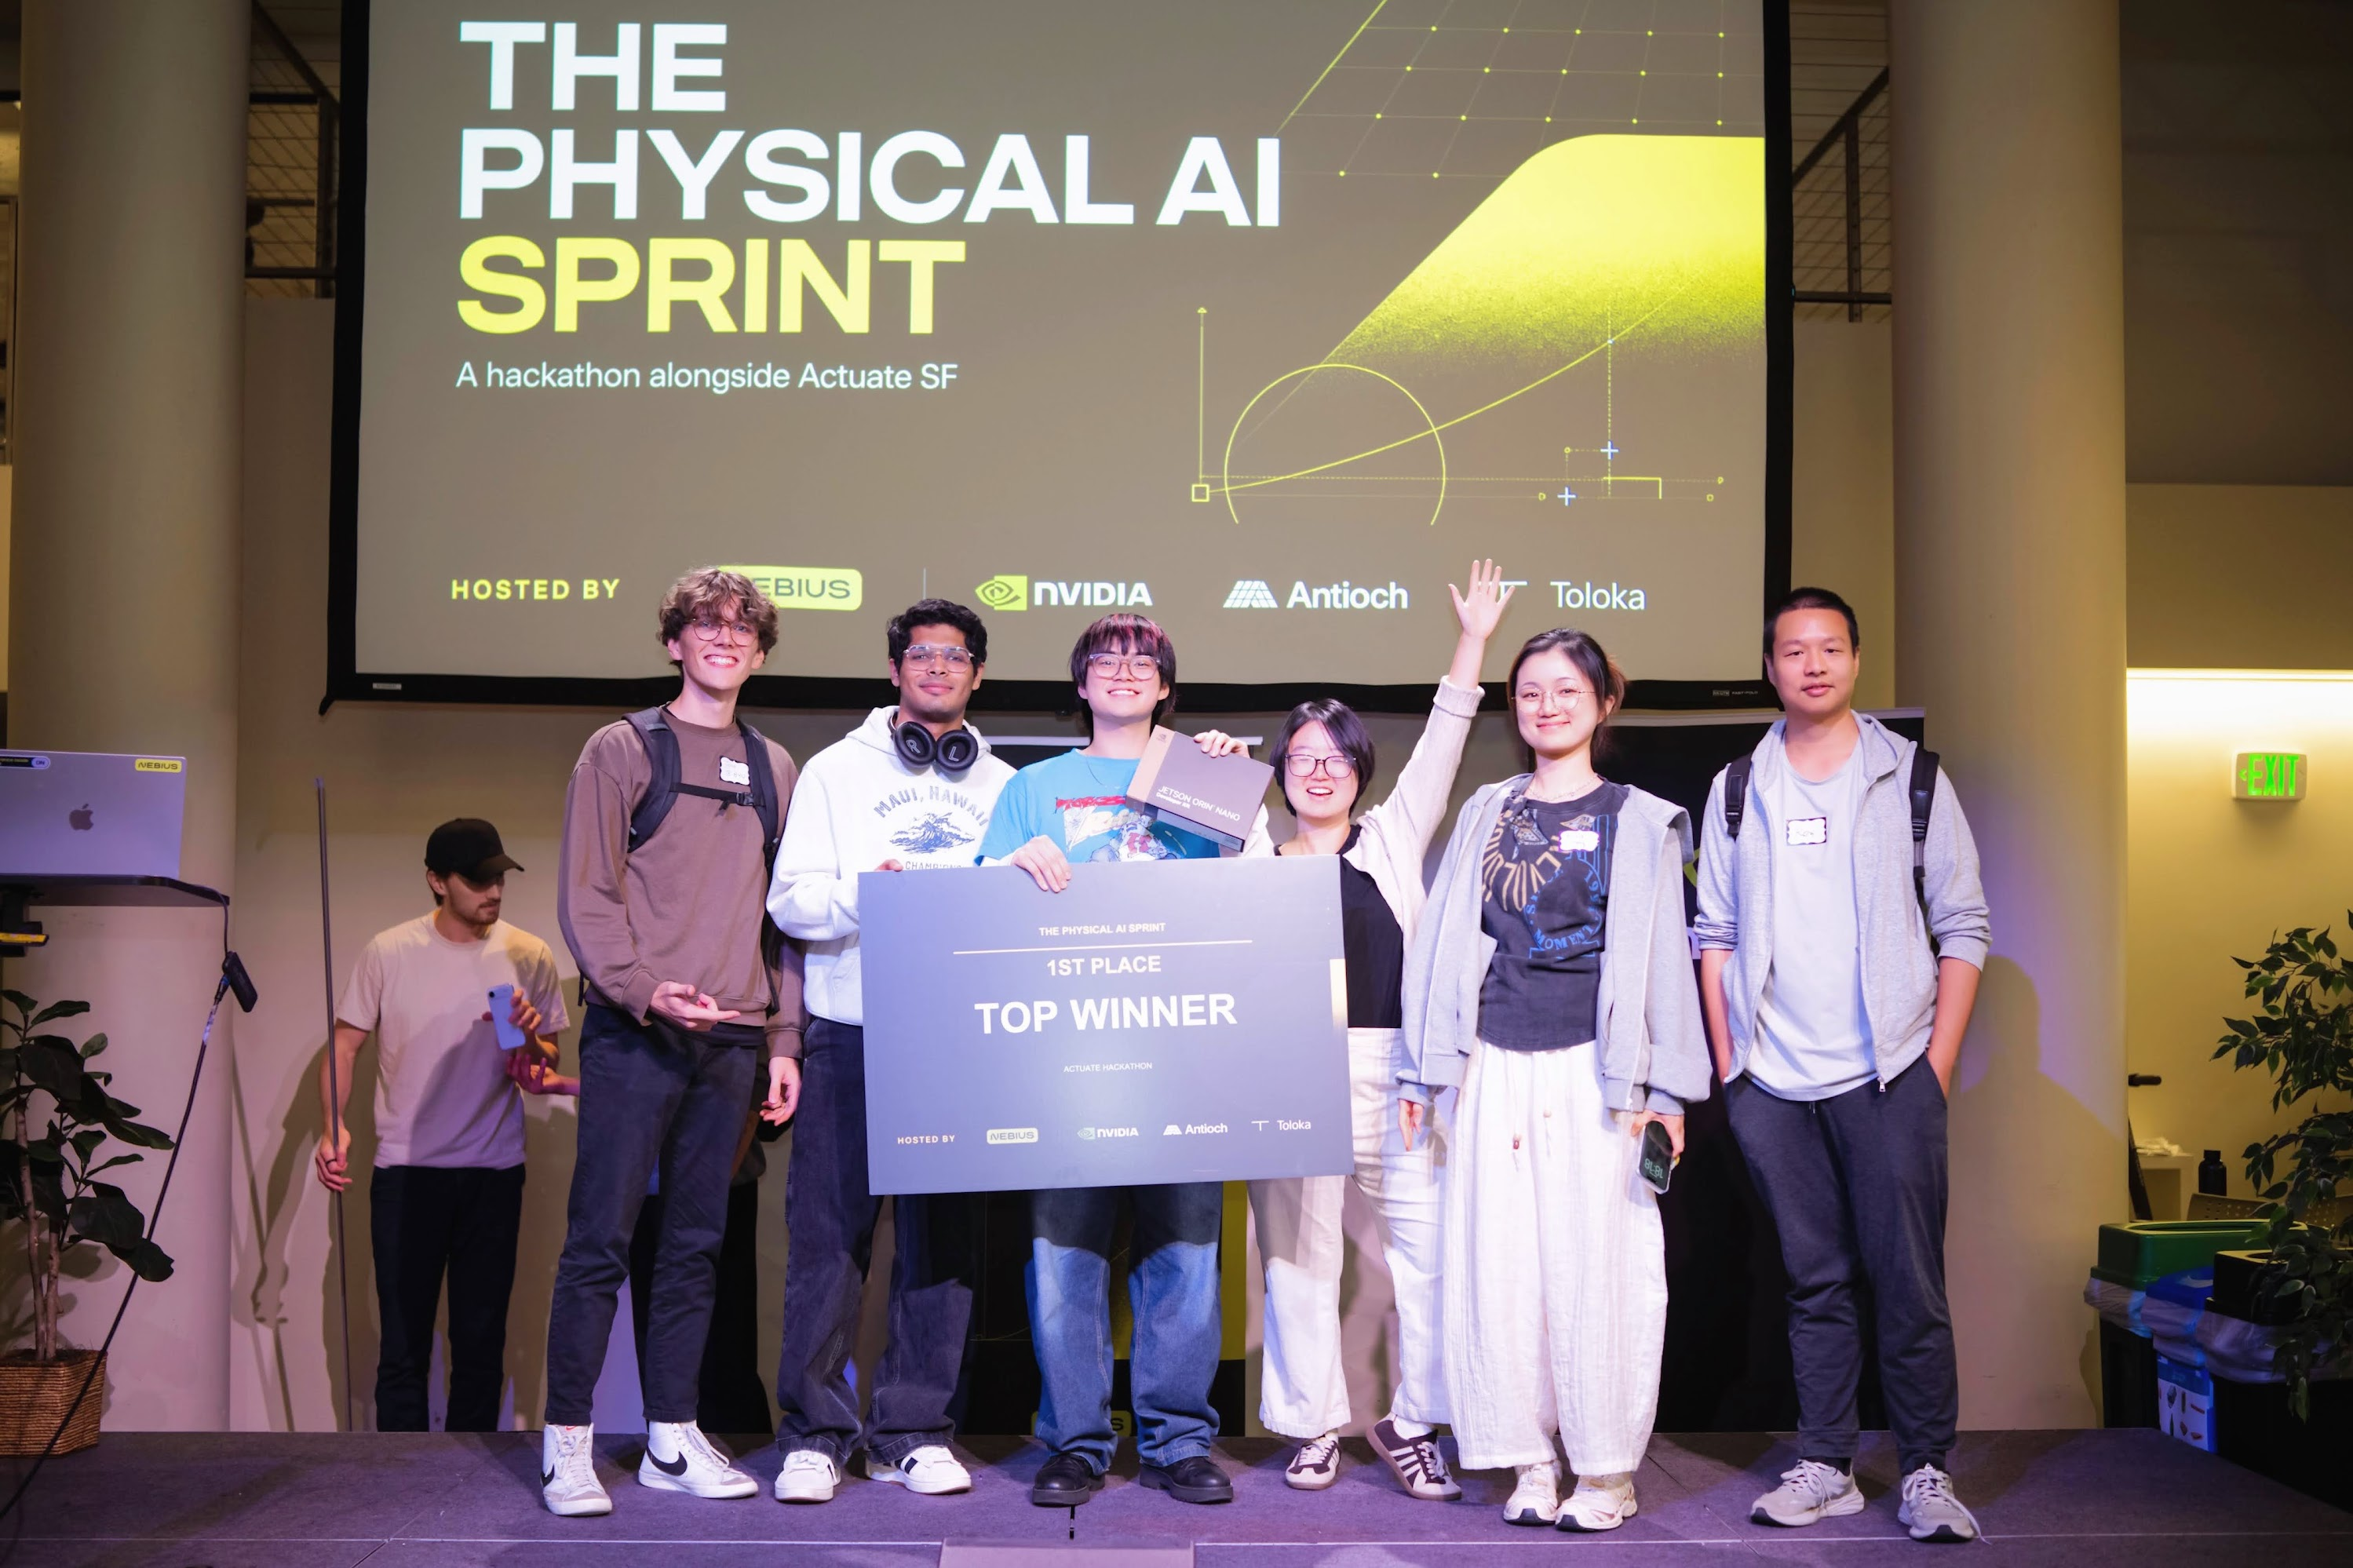
Physical AI — Robot Integration & Evaluation
1st Place · Physical AI Hackathon · 2026
Our team won the NVIDIA × Nebius × Antioch × Toloka Physical AI Hackathon with a vision-language-action evaluation and retraining workflow.
- Built and tested a control harness intended to connect model actions to LeRobot, with action validation, command clamping, and explicit control intents.
- Investigated platform, device-mapping, and serial-connection limitations. The final demo ran the frontend and backend; the physical robot connection remained incomplete.
Experience
Robotics Research Assistant
FRoST
- Organizing DB3-to-MCAP conversion with AI coding agents, selecting data to retain, and investigating timing issues and dataset usability
- Setting up website documentation, contributing the paper’s data structure section, and evaluating dataset hosting options
RoboBoat Perception Lead
Brigham Young University
- Leading the perception team’s technical direction and turning system requirements into implementation tasks
- Guiding architecture and evaluating approaches for sensor fusion, state estimation, and vision-based detection
- Overseeing ROS 2 node responsibilities and interfaces across the perception system
Research Assistant — Multi-Agent Planning & Optimization
BYU IDeA Labs
- Developed a multi-agent grid path planner that achieved 97–99% of full-horizon coverage with a 2.5–10× runtime reduction
- Proved a 50% approximation guarantee for a robust round-robin resource planner against the optimal solution
- Identified failure conditions for adjacency-constrained path-planning guarantees
Research Assistant — Quantum Photonics Simulation
BYU Electrical Engineering Department
- Contributed to a team effort to optimize a Julia simulation engine for hybrid Gaussian and non-Gaussian quantum-optics states
Research Assistant — Econometrics
BYU Economics Department
- Built statistical-modeling and large-scale data-preparation workflows in Python and Stata for causal-inference research
- Supported reproducible quantitative analysis of relationships between language learning and career outcomes
Education
B.S. in Applied and Computational Mathematics
Brigham Young University
- Major GPA: 4.00/4.00
- BYU Merit Scholarship
- AI Association team lead and Competitive Programming Association member
- ACME core curriculum: mathematical analysis, algorithm design and optimization, probabilistic modeling, and dynamical systems and control